


RLDX-1 from Real World (RLWRLD) is a dexterity-first foundation model for robot hands, announced on Wednesday May 13 at the SF Exploratorium. RLWRLD is targeting the manufacturing and logistics market but many of the benchmark tasks and capabilities displayed are essential for household and service robotics as well.
The launch event combined solid demos with interesting panel discussions led by RLWRLD President Carl Choi and featuring Amit Goel, Head of Robotics and Edge AI at Nvidia and the founders of RLWRLD, WiRobotics, Enactic, Origami Robotics and Proceptive. Here’s an event write up from Won Hoseob at Maeil Business.


Amit Goel was pleased to see RLDX-1 exceeding the performance of Groot on a range of benchmarks, from standards like Libero and Simpler that these days lack relevance for robotics models, to more challenging and realistic tasks from RoboCasa and the DexBench set of 18 tasks with 55 evaluation cases developed by RLWRLD.
“Benchmarks are the pathway from measurability to reliability,” said Amit Goel, “and their purpose is to translate research into industry viability.” (paraphrased)
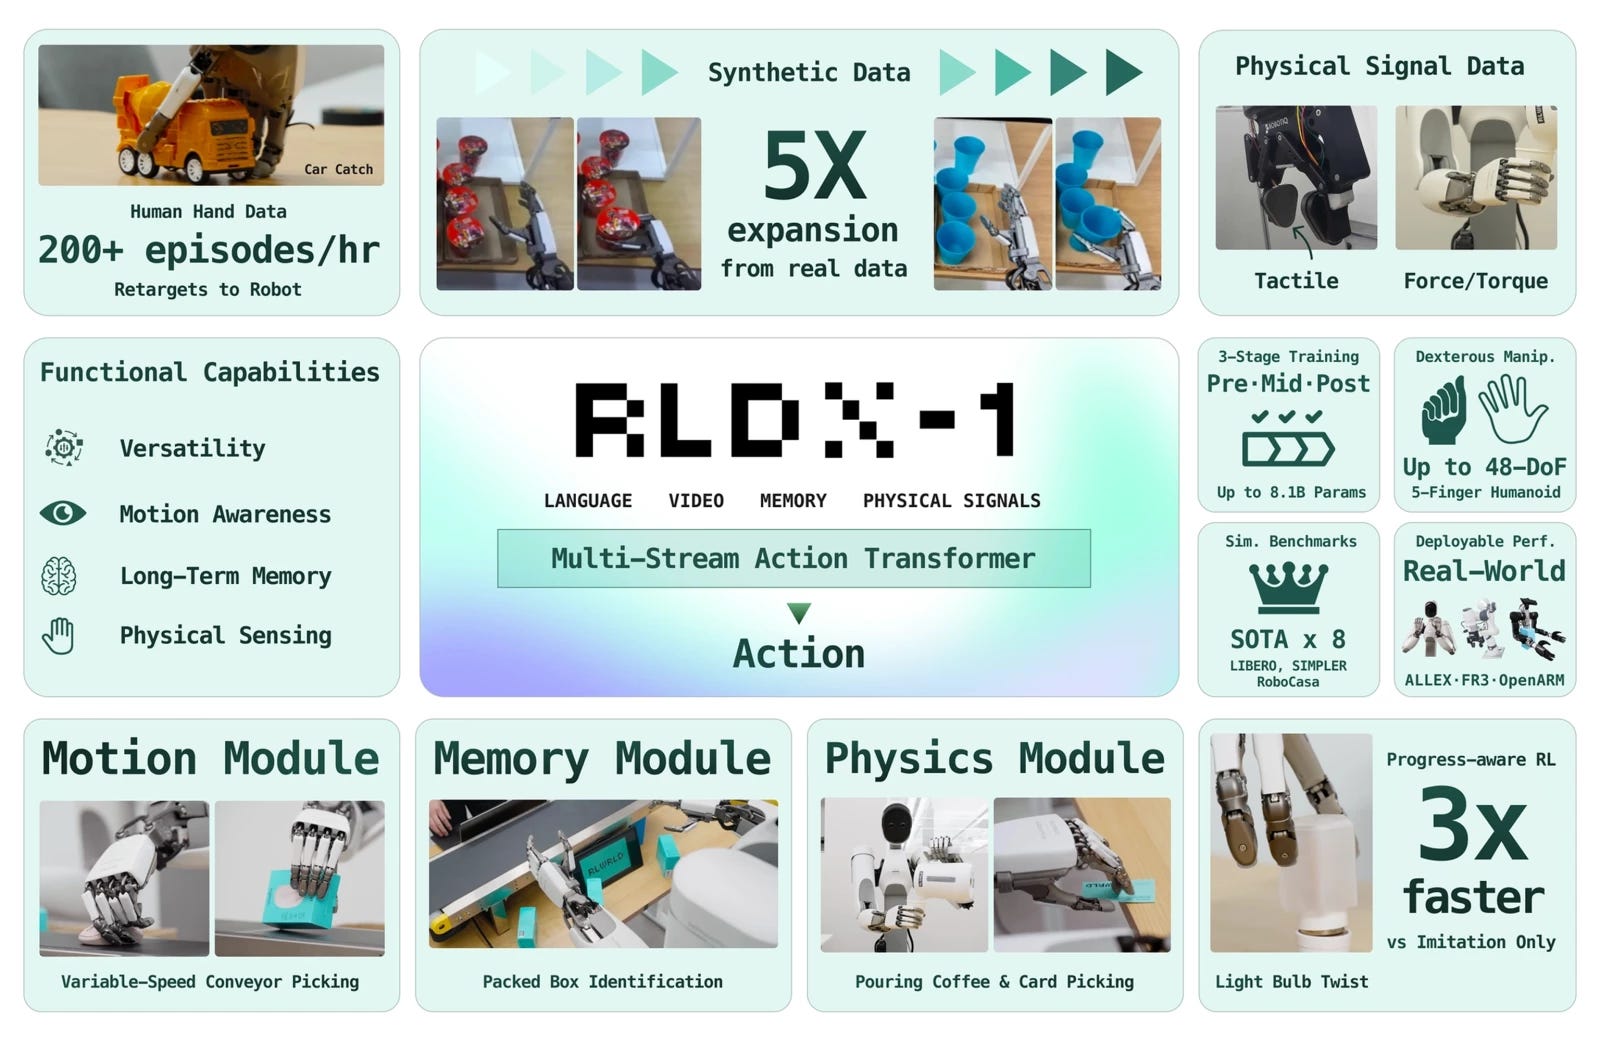
Scale may be the ultimate answer towards developing human-level artificial intelligence across all domains, however current large scale models lack real world physics and interaction data. As RLWRLD say “you can’t scale what you can’t see”.
Scale will remain a powerful lever. But when we deployed the best available VLAs (Vision-Language-Action models) on the tasks our customers actually need (pouring, in-hand rotation, reactive grasping), they failed consistently, not because they lacked intelligence, but because the task lived in modalities the model was never given: high-DoF hand-object geometry, contact forces, temporal dynamics. Scale cannot recover a modality the model was never given in the first place.
The architecture of RLDX-1 incorporates a Multi-Stream Action Transformer resulting in a single model that can see, feel, remember, and adapt, deployable across single-arm, dual-arm, and humanoid embodiments with high-DoF hands. Not only is RLDX-1 translatable across hands and arms, but the Multi-Stream Action Transformer uses less energy and provides balanced performance without model collapse.
The prevailing assumption in the field is "intelligence first, dexterity follows." Our experience points the other way. Dexterity is not what comes after intelligence; it is the path intelligence takes when it has to act in the physical world. The deciding signal can live in torque, tactile, depth, or modalities with no human analogue, and scaling vision pre-training does not conjure what was never in the pixels. What scales for embodied intelligence is the number of modalities a model can absorb and let complement each other, not the size of any single one.
Vincent Duchaine from Robotiq articulated this very clearly in an April post “Vision-only manipulation is hitting a wall”
“Before contact, the robot is working off images. After contact, it’s dealing with forces.”
Vision sees outcomes. Contact sensing measures interaction as it happens, which is where the useful data lives. Physical AI improves with more data, but not all data matters the same. Force and tactile signals have an outsized impact on how well a system handles real contact.
“Most datasets still lean heavily on vision and joint data.”
So you see the same pattern over and over. Robots reach the right position. Then struggle with insertion, assembly, and anything that depends on compliance. The missing information is physical.
Everyone knows OpenArm, the open-source 7DOF humanoid arm designed for physical AI research and deployment in contact-rich environments. It’s now the most downloaded/built/purchased robot arm since Hugging Face and Pollen Robotics SO-101. OpenArm was created by Enactic, and after hearing CEO Hiroto Yamamoto speak at the RLWRLD event, I realized that OpenArm is just part of Enactic’s journey towards creating human assistance and care-giving robots. Humanoids that care.
I also spent some time this week with DOT Inc, a KAIST spinoff that is a leader in tactile display technology, particularly useful for anyone with visual impairments. However, the underlying miniature linear actuators developed by DOT Inc have applications well beyond dynamic braille displays. DOT Inc’s actuators are ideal for teleoperation with haptic feedback, or data collection and tactile sensing for robot hands, or the whole humanoid body.
KAIST is certainly kicking ass atm in converting robotics research into real world applications. RLWRLD has deep connections to KAIST as does DOT Inc. Humanoid robot company Rainbow Robotics, founded by Professor Jun-Ho Oh, is another high profile spinout which successfully went public and was then acquired by Samsung.
Some of the other notable KAIST startups include: ROEN Surgical, which develops minimally invasive flexible surgical robots designed for kidney stone removal, gastrointestinal procedures, and microsurgeries, founded by Dr. Dong-Soo Kwon; Angel Robotics, a company specializing in rehabilitation and medical robots founded by Professor Kyung-chul Kong; Pureun Robotics; Wero Robotics; Raion Robotics ; Triangle Robotics; URobotics; and Diden Robotics.
It’s not just KAIST, Professor Kyujin Cho of Seoul National University is planning on transforming the global robotics startup ecosystem. He is the incoming President of the IEEE Robotics and Automation Society, after many years of transformative leadership as VP of Technical Activities and Conference Activities. Kyujin Cho is now focused on expanding the RAS entrepreneurial programs developed during my terms as VP of Industry Activities.


Busy week! At RLWRLD’s event I finally had a chance to hang out with the amazing Andie Zhang, Global Portfolio and Technology Manager for Collaborative Robots at ABB. I’ve admired Andie’s leadership and deep experience in real world robotics for many years now. I’m looking forward to her insights in the new Davos Robot City Award.
Introducing the Robot City Award Jury 🏆
This July in Davos, 30+ robotic systems will operate live across the city, in public, in real conditions. Eight of the most credible minds in Physical AI will observe them in the field and decide who wins.
I also got to share a stage with Steve Wozniak at Silicon Valley Camp at the 1440 Multiversity. took part in an interesting panel with Alex Ivanenko, CEO of The Lithium Company; Michael Harries, Partner at the Robotics Hub Fund; Alex Dantas, CEO of Circuit Launch and Alexander Samogin, AI Infrastructure at Google. It’s not surprising that we talked a lot about manufacturing, energy and data centers.
I also gave a keynote on humanoid robots. For a change, the humanoid robots were totally upstaged by Steve Wozniak. I hadn’t realized that he was still an Apple employee, and actually never left the company at any stage. That’s loyalty.
Finally, Louis Lehot of Foley & Lardner has written a great recap of the talk I gave at Vitaly Golomb’s Hard Things Salon : “From Punchline to Platform: Hard Things Round Two and the Real History of Robotics”
Round Three is a Salon with President and COO of Serve Robotics Touraj Parang. Request your invite here.
From the Graveyard of Robot Startups:
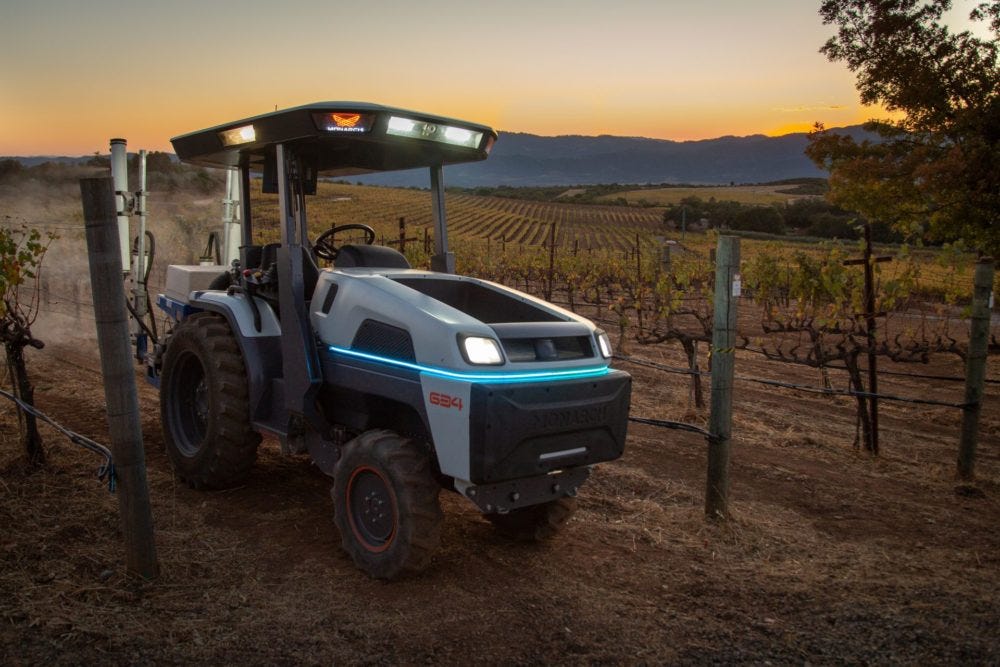
Monarch Tractor CEO—‘We should have pivoted harder and faster’ an AgFunder Exclusive
When a funded robotics startup fails there are usually complicating financial, business model and operational reasons, not simply a product/market fit problem, a team problem or a technology problem.
Monarch Tractor’s collapse reflects the limits of an ambitious full-stack hardware model in a changing economic climate—not a failure of the underlying technology, insists cofounder Praveen Penmetsa.
The pandemic pushed many potentially successful robotics startups over the edge as customers closed down or scaled back operations. In 2022, the Federal Reserve interest rate jump from near 0% to 4.25%–4.50% to combat 40-year high inflation caused significant technology investor behavior changes. The more recent addition of erratic tariffs have caused component prices to rocket and the supply chain to become more unpredictable.
A complex technology startup, like robotics, needs to navigate the global weather without mistakes, as well as solving for the core operations, technology and business model solutions. In many ways, it’s a credit to Monarch Tractor that they survived from 2018 to 2026.
Read all the details at AgFunder.
IEEE Humanoids 2026 - Call for Workshops
What: 2026 IEEE RAS International Conference on Humanoid Robots
When: December 6-9, 2026
Where: Santa Clara, California, USA
Web: https://2026.ieee-humanoids.org
We are very pleased to invite you to contribute proposals for half-day or full-day workshops/tutorials to the 2026 IEEE RAS International Conference on Humanoid Robots to be held December 6-9, 2026 in Santa Clara, California, USA.
WORKSHOPS & TUTORIALS: The workshop and tutorial sessions are aimed at exploring the frontiers of recent or emerging topics related to humanoid robotics, with relevant topics detailed below. We encourage workshops and tutorials that will promote exchanges and interactions between presenters and participants. Proposals with a diverse set of speakers, including a balance between (i) junior and senior presenters, (ii) genders, (iii) geographic location, (iv) race and ethnicity, and (v) industry and academia, will be preferred.
OVERVIEW: Humanoids 2026 aims at bringing together top researchers from humanoid robotics and related disciplines with leading companies in the field. In light of a year of rapidly evolving humanoid technologies with several new platforms coming onto the market and bringing us closer to a wider real-world deployment. Our community envisions innovative areas in humanoid robotics that lie at the intersection of general-purpose physical, cognitive, and motor capabilities, while also considering the scientific understanding of interactions with humanoid and anthropomorphic systems.
SCHEDULE: The conference will be organized as a 4-day event opening on December 6th (Sunday) with public panels, seminars, and hackathons, followed by workshops and tutorials on December 7th (Monday), followed by 2 days December 8th-9th (Tuesday-Wednesday) for the main conference with plenaries, keynotes, oral and interactive sessions, and industry events. A centrally located exhibition will feature the latest humanoid technology from both industry and academia.
EXHIBITION: Industry leaders are eager to see your organization’s latest developments, connect, learn, and collaborate. Don’t miss this opportunity to make a strong, in-person impression. For more information contact Hall-Erickson, Inc: humanoids@heiexpo.com
MORE INFORMATION: For more information, please visit the conference contributions webpage (https://2026.ieee-humanoids.org/call-for-workshops-and-tutorials) or contact the Workshop Chairs: Enrico Mingo Hoffman, Yan Gu, and Rafael Cisneros-Limón (humanoids2026-wt@ieee.org).
We look forward to your contributions to Humanoids 2026!
—
The Humanoids 2026 General Chairs:
Andra Keay (Silicon Valley Robotics)
Ross Mead (Semio)
IEEE Entrepreneurship Hard Tech Venture Summit - Boston
June 10-11, 2026 - Thomas M. Menino Convention and Exhibition Center (MCEC)
Boston, MA
Fueling Hard Tech growth through capital, mentorship, and resources. Designed specifically for Pre-Seed to Series A startups building complex physical technologies.
See what attendees experienced at April 2026 Summit
See what our attendees experienced at last year’s Summit
Why Attend?
High-Impact Engagement: Historically maintains a 2:1 startup-to-investor ratio.
Roundtable Discussions: Unique opportunities to connect directly with investors.
Technical Problem Solving: Receive hands-on guidance from manufacturing experts to solve hurdles.
Strategic Partnerships: Accelerate fundraising, production, and market entry.
Silicon Valley Robotics Investor/Startup Database
Are you a startup fundraising atm? Fill out our “For Investors Eyes Only” sheet.
These investors write checks anywhere from angel and seed stage to $5-50 million.
Feedback from the startups - high quality inbound interest from investors.
Feedback from the investors - incredible depth and range of robotics startups.
If you’re an accredited investor and haven’t already signed up for the spreadsheet - Sign up here for great robotics deal flow!
Robotics News
Rivian spinoff Mind Robotics raises another $400 million - TechCrunch
Inside China’s race to dominate the humanoid robotics industry - NBC News
Can a Chinese EV-maker reinvent itself as a robot firm? - The Economist
Unitree’s New Giant Mecha Robot Can Smash Through Walls and Seat a Human Pilot. Here’s What You Need to Know - Yahoo Finance
Hospital says RFK Jr. did not operate robotic arm during heart surgery - The Hill
Heavy Robotic Machinery Operates Itself plus Your weekly selection of awesome robot videos - IEEE Spectrum
Bay Area Robot Wars Are Becoming Dance Battles - SF Standard
Anduril lands $5B as defense giant builds autonomous warship operation in Seattle - Geekwire
Robots for America Launches National Coalition to Advance U.S. Robotics Deployment Policy - Business Wire
Robotics Events
Want to host an event or reach the robotics community?
Many companies are reaching out to Silicon Valley Robotics about hosting events, outreach or hiring and we have a great community network, of people looking for work, of investors interested in deal flow and of technologists interested in learning about the latest advances.
Would you be interested in hosting the next Bots, Bevs and Devs? Or something customized specifically for your goals? Reach out here!
More Robotics Events:
Robotics Invest - Boston - May 26-27
ICRA 2026 - Vienna, Austria - June 01 - June 05
IEEE Hard Tech Venture Summit - Boston - June 10 - June 11
Automate - Chicago - June 22 - June 25
Deep Tech Week - San Francisco - June 22 - June 26
Robot Fringe Festival - London - July 2
Robotics: Science and Systems - Sydney, Australia - July 13 - July 16
Open Sauce - San Francisco - July 17 - July 19
Actuate - San Francisco - Aug 18 - Aug 19
ROSCon Global - Toronto - Sep 22 - Sep 24
IROS 2026 - Pittsburgh - Sep 27 - Oct 1
IEEE Humanoids 2026 - Silicon Valley - Dec 6-9
The annual IEEE-RAS International Conference on Humanoid Robots is the internationally recognized prime event of the humanoid robotics community. The conference is sponsored by the IEEE Robotics and Automation Society and coordinated by the Technical Committee on Humanoids.
Mountain View Technology Showcase 2026
Call for Makers Application
July 30, 2026
11:00AM - 3PM
Mountain View Civic Center Plaza -- 500 Castro Street
The Technology Showcase is a unique opportunity for local Mountain View tech-oriented companies and makers to showcase their ideas and products to a wide audience. Whether you are an entrepreneur, startup, or established business, this wildly popular annual event attracts hundreds of potential customers, influencers, and investors. For no cost to you, you can have a booth at the event and showcase your technology.
The one day outdoor event takes place in Downtown Mountain View and is free to the public.
- Exhibitor Booth Includes: 10x10 space, 6ft table, white table cover, 2 chairs
Application deadline is June 22, 2026
Questions please reach out to marisol@chambermv.org
Send me your 2026 progress, plans or posts for potential inclusion in Robots&Startups. Or join the organizing team at Silicon Valley Robotics - bots&beer@svrobo.org


The RLDX-1 discussion reinforces a critical shift in robotics: embodied intelligence will not be solved by vision-language scale alone, but by integrating tactile, force, temporal, and high-DoF interaction data. Dexterity is not downstream of intelligence; it is one of the core pathways through which physical AI becomes commercially reliable.
The line that scale cannot recover a modality it never received applies beyond robotics. In knowledge work, a model may see the document but miss the conversation, exception, or field judgment that gave it meaning. Benchmarking should therefore test whether the system recognizes absent evidence, not only whether it succeeds on complete inputs. Do current dexterity benchmarks reward an explicit 'insufficient sensing' response, or do they still push models to act even when the decisive modality is unavailable?